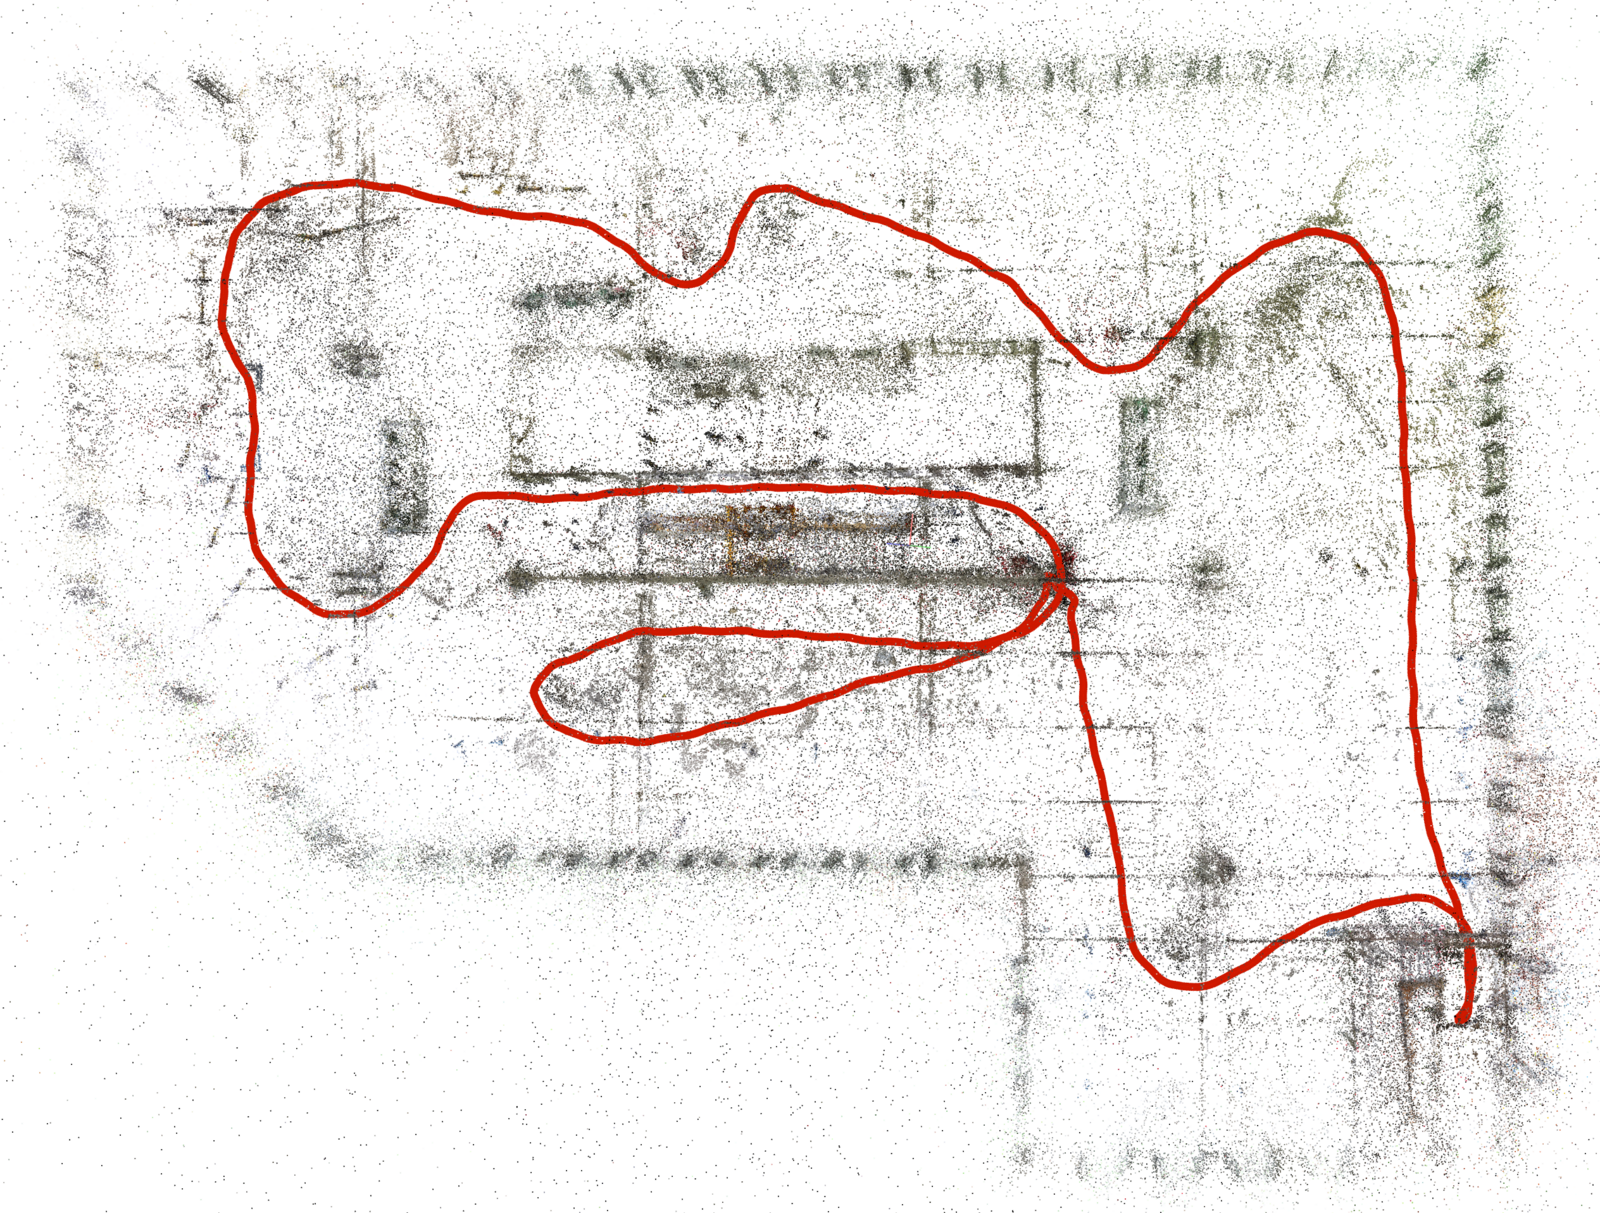
Establishing the Gold Standard for 360° Visual-Inertial Reconstruction

Hilti × Trimble SLAM Challenge 2026

This project was carried out as part of the 3D Vision course (2026) at ETH Zürich with the Computer Vision and Geometry Group, as our entry to the Hilti × Trimble SLAM Challenge 2026. Task. Produce a metric, gravity-aligned, floorplan-consistent trajectory and 3D map on the Hilti × Trimble SLAM Challenge 2026 indoor dual-fisheye + IMU dataset. Problem. OpenVINS drifts on long indoor traverses with repetitive textures. Our solution combines two pipelines on top of the VIO trajectory — a lightweight COLMAP bundle-adjustment refinement and a full panorama SfM from scratch with tightly-coupled visual-inertial bundle adjustment — plus a unified 2D ICP post-processing step that aligns both outputs to the building floorplan. ...
June 12, 2026 · 4 min · Gilbert Tanner
SAPIENCE - Sense & Avoid - a cooPeratIvE droNe CompEtition

SAPIENCE - Sense & Avoid - a cooPeratIvE droNe CompEtition

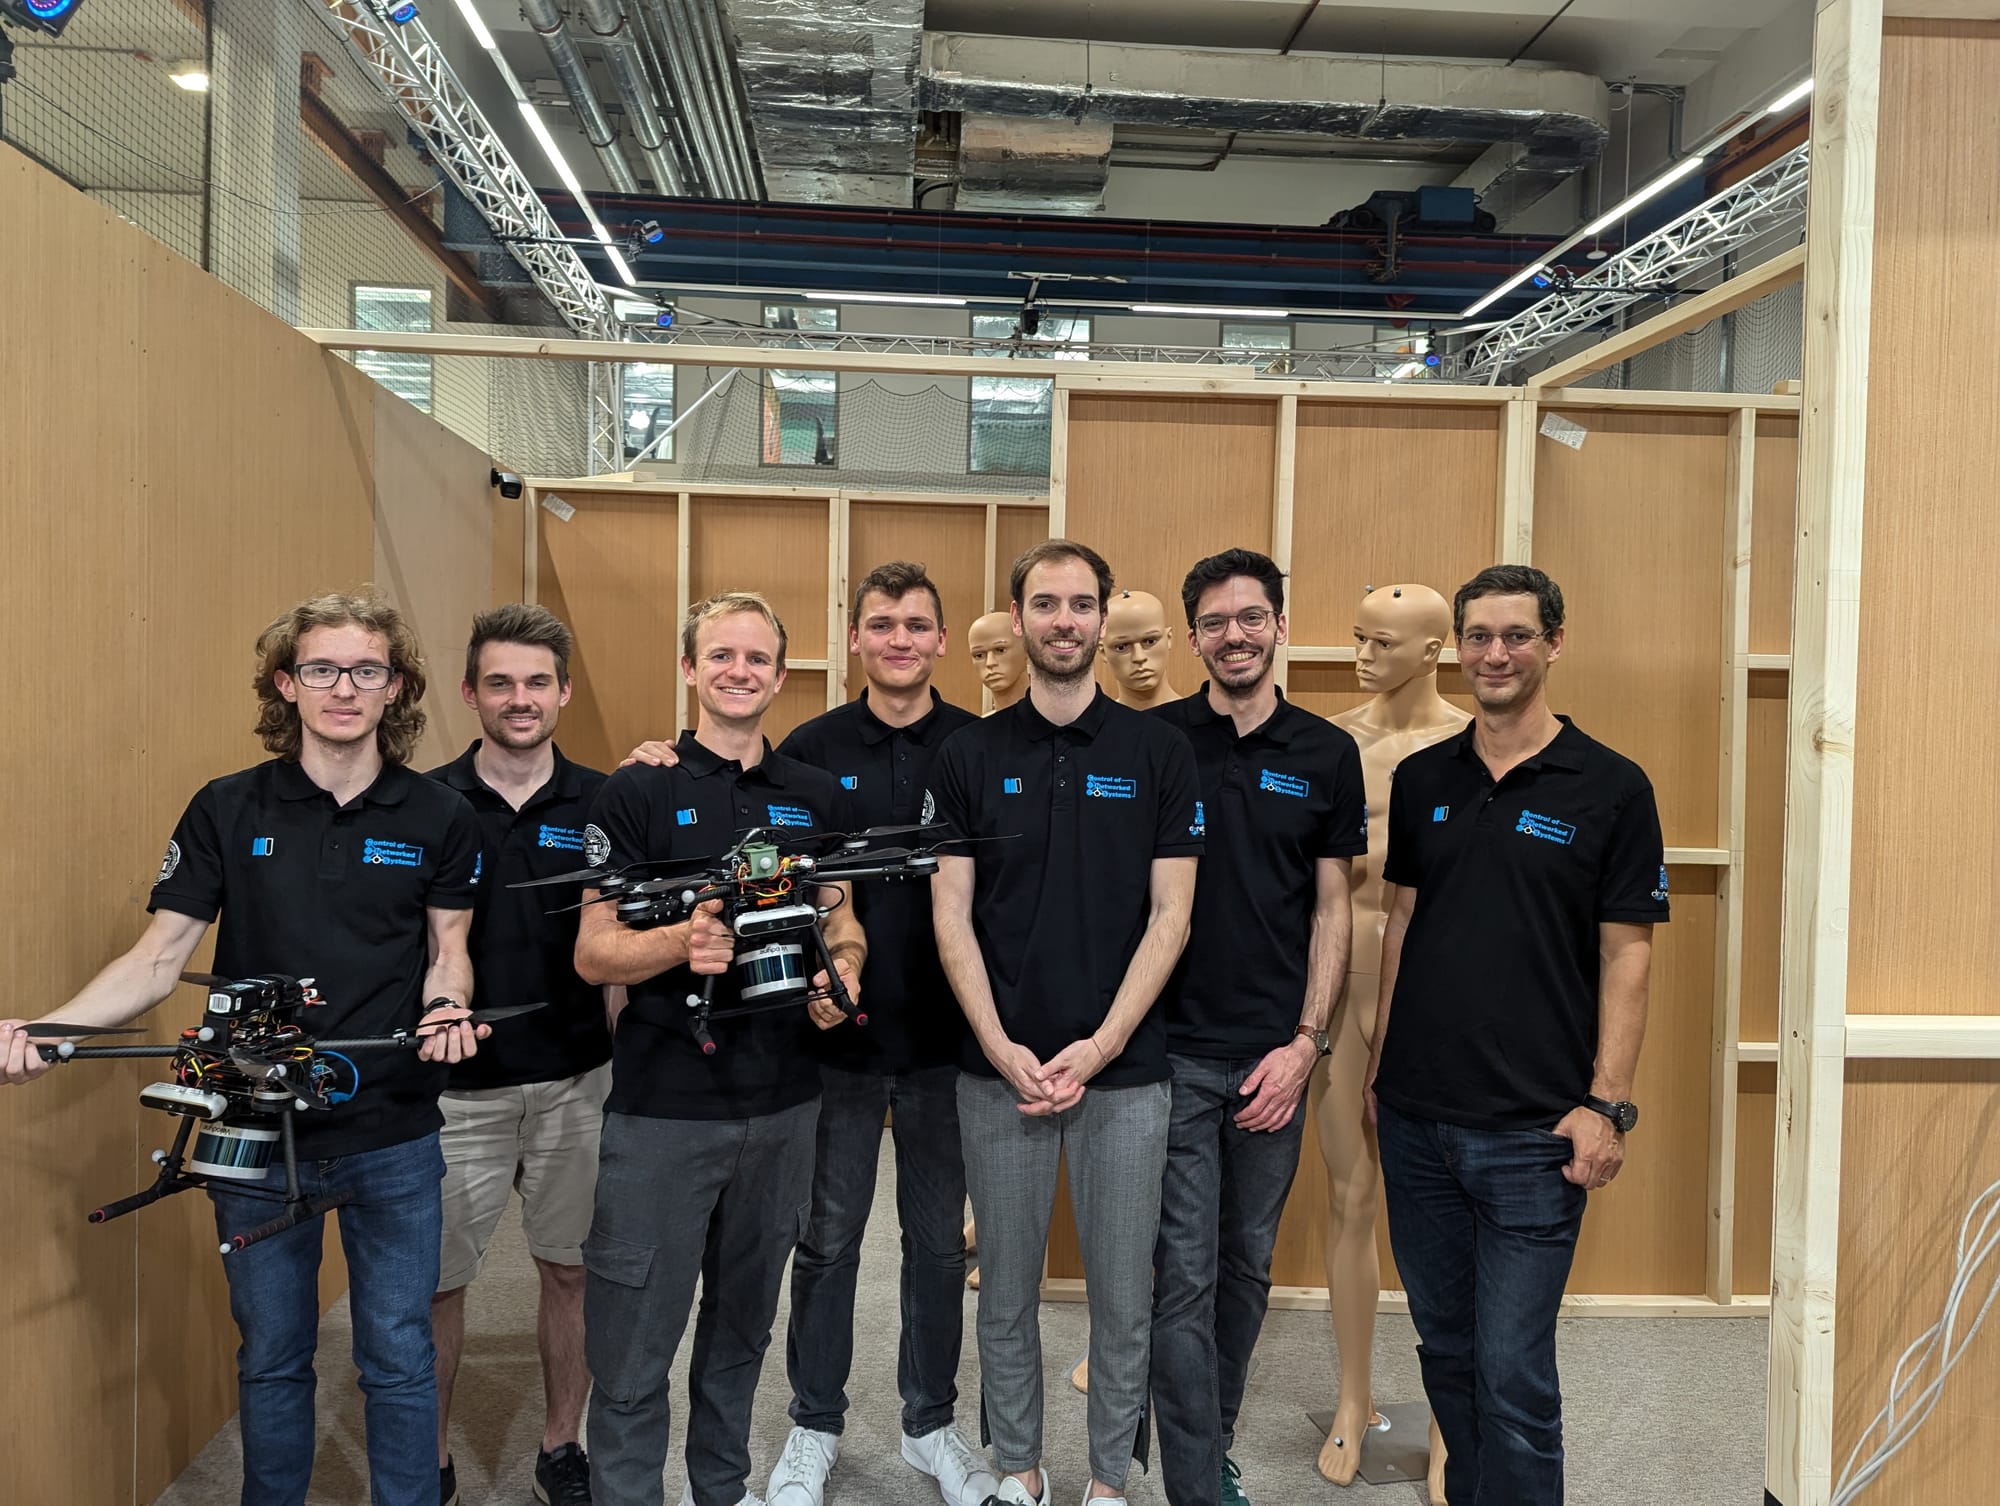
Competition 1: Indoor Mapping and Object Detection Result: 2nd place (London, August 2024) Tasks: Mapping the Environment - Construct a map using two drones, navigating various hazards.Object Detection - Detect and note positions of objects like hazardous containers and injured mannequins.Aid Delivery - Deliver aid packages to mannequins at specific locations.Team Klagenfurt: Gilbert TannerLuca Di PiernoGeorg SteinthalerTim SchumannBen WesseJonas SpielerSupervisor: Prof. Stephan WeissThe competition occurred on 29th-30th August 2024 in London and Team Klagenfurt was able to solve all three tasks as specified above. To navigate the indoor environment we made use of ICP odometry based on RTABMAP fusing PointCloud data from the 3d lidar and depth camera. The environment was explored using 3d frontier exploration. ...

November 15, 2024 · 4 min · Gilbert Tanner