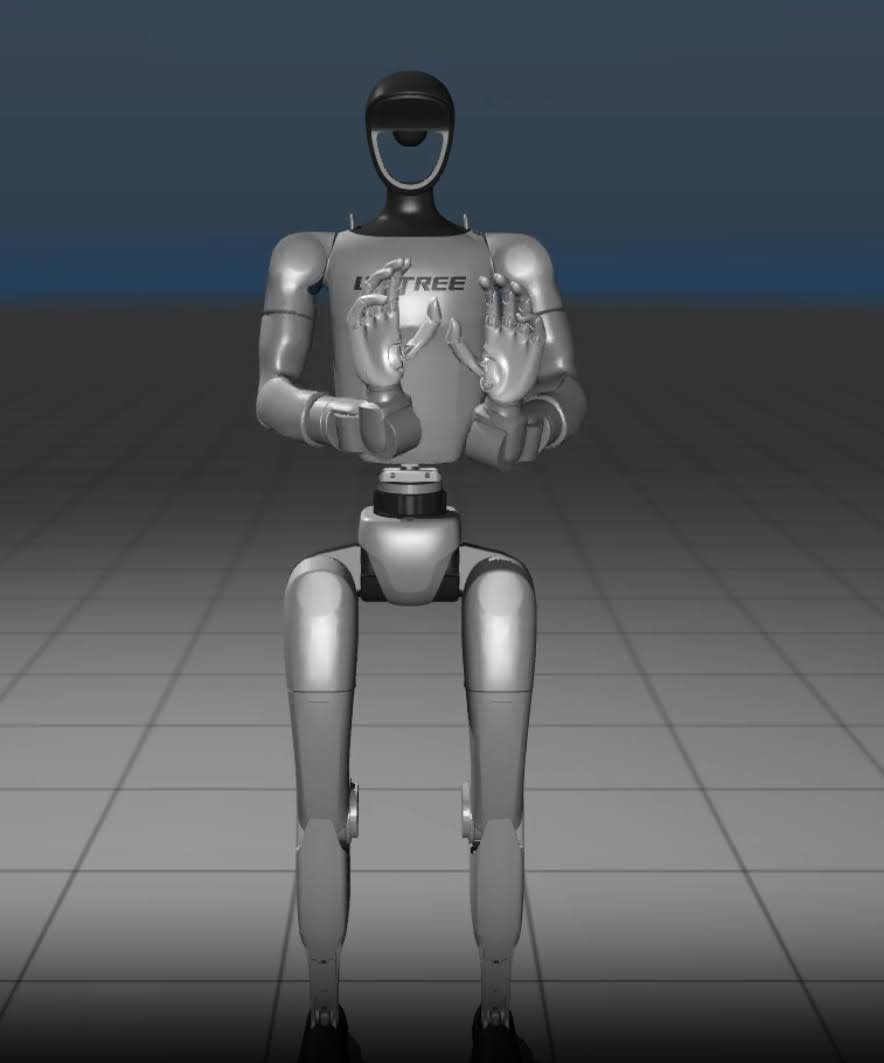
Sign Language Interpreter

Sign Language Interpreter

This is my semester project for my Robotics, Systems and Control Master's at ETH Zurich, carried out from February to August 2026. The goal is to build a system that converts spoken language into continuous sign language motions for a humanoid robot. Sign language interpretation is essential for accessibility but the availability of professional interpreters is limited. A robotic interpreter could offer a scalable alternative by translating speech into sign language in real time. ...
February 24, 2026 · 1 min · Gilbert Tanner
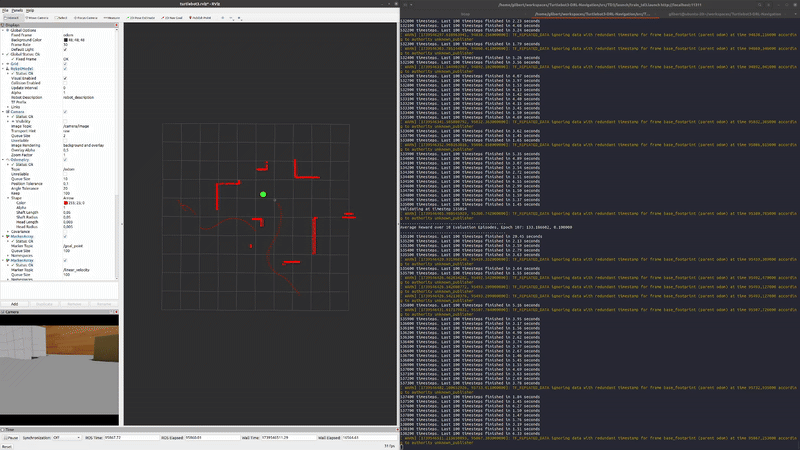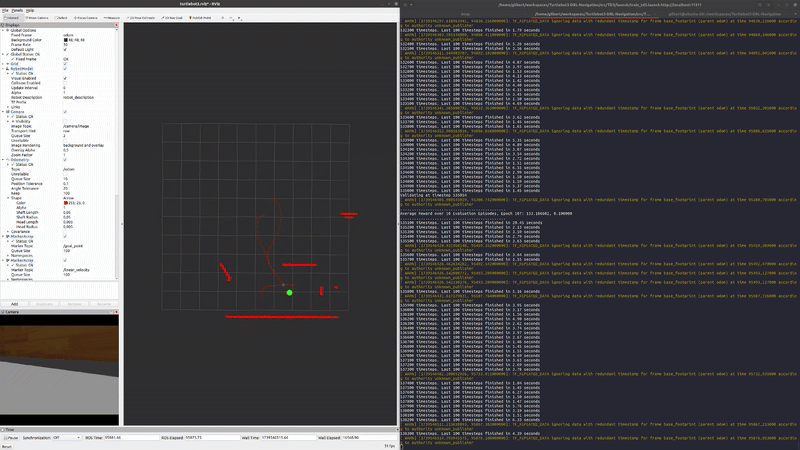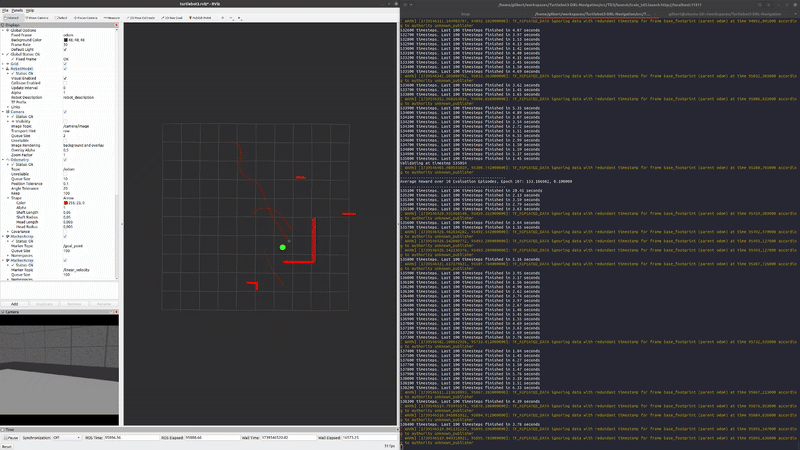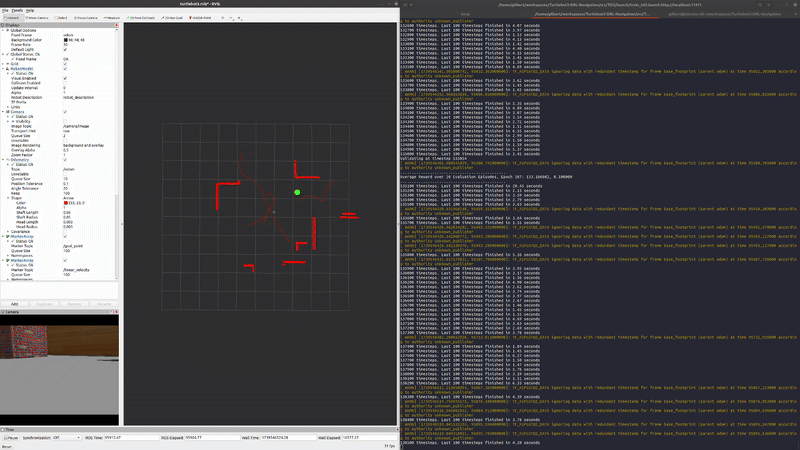
Turtlebot3 DRL Navigation

Turtlebot3 DRL Navigation

Extended an existing Deep Reinforcement Learning navigation framework to support the TurtleBot3 platform with realistic 2D LiDAR observations, and migrated the full system from ROS 1 to ROS 2. The project enables training DRL agents for goal-directed mobile robot navigation with obstacle avoidance in Gazebo, using LiDAR-based state representations and velocity-based control tailored to TurtleBot3 kinematics. To accelerate experimentation, the simulation can be executed at increased real-time factors while maintaining stable learning dynamics. ...

February 27, 2025 · 1 min · Gilbert Tanner