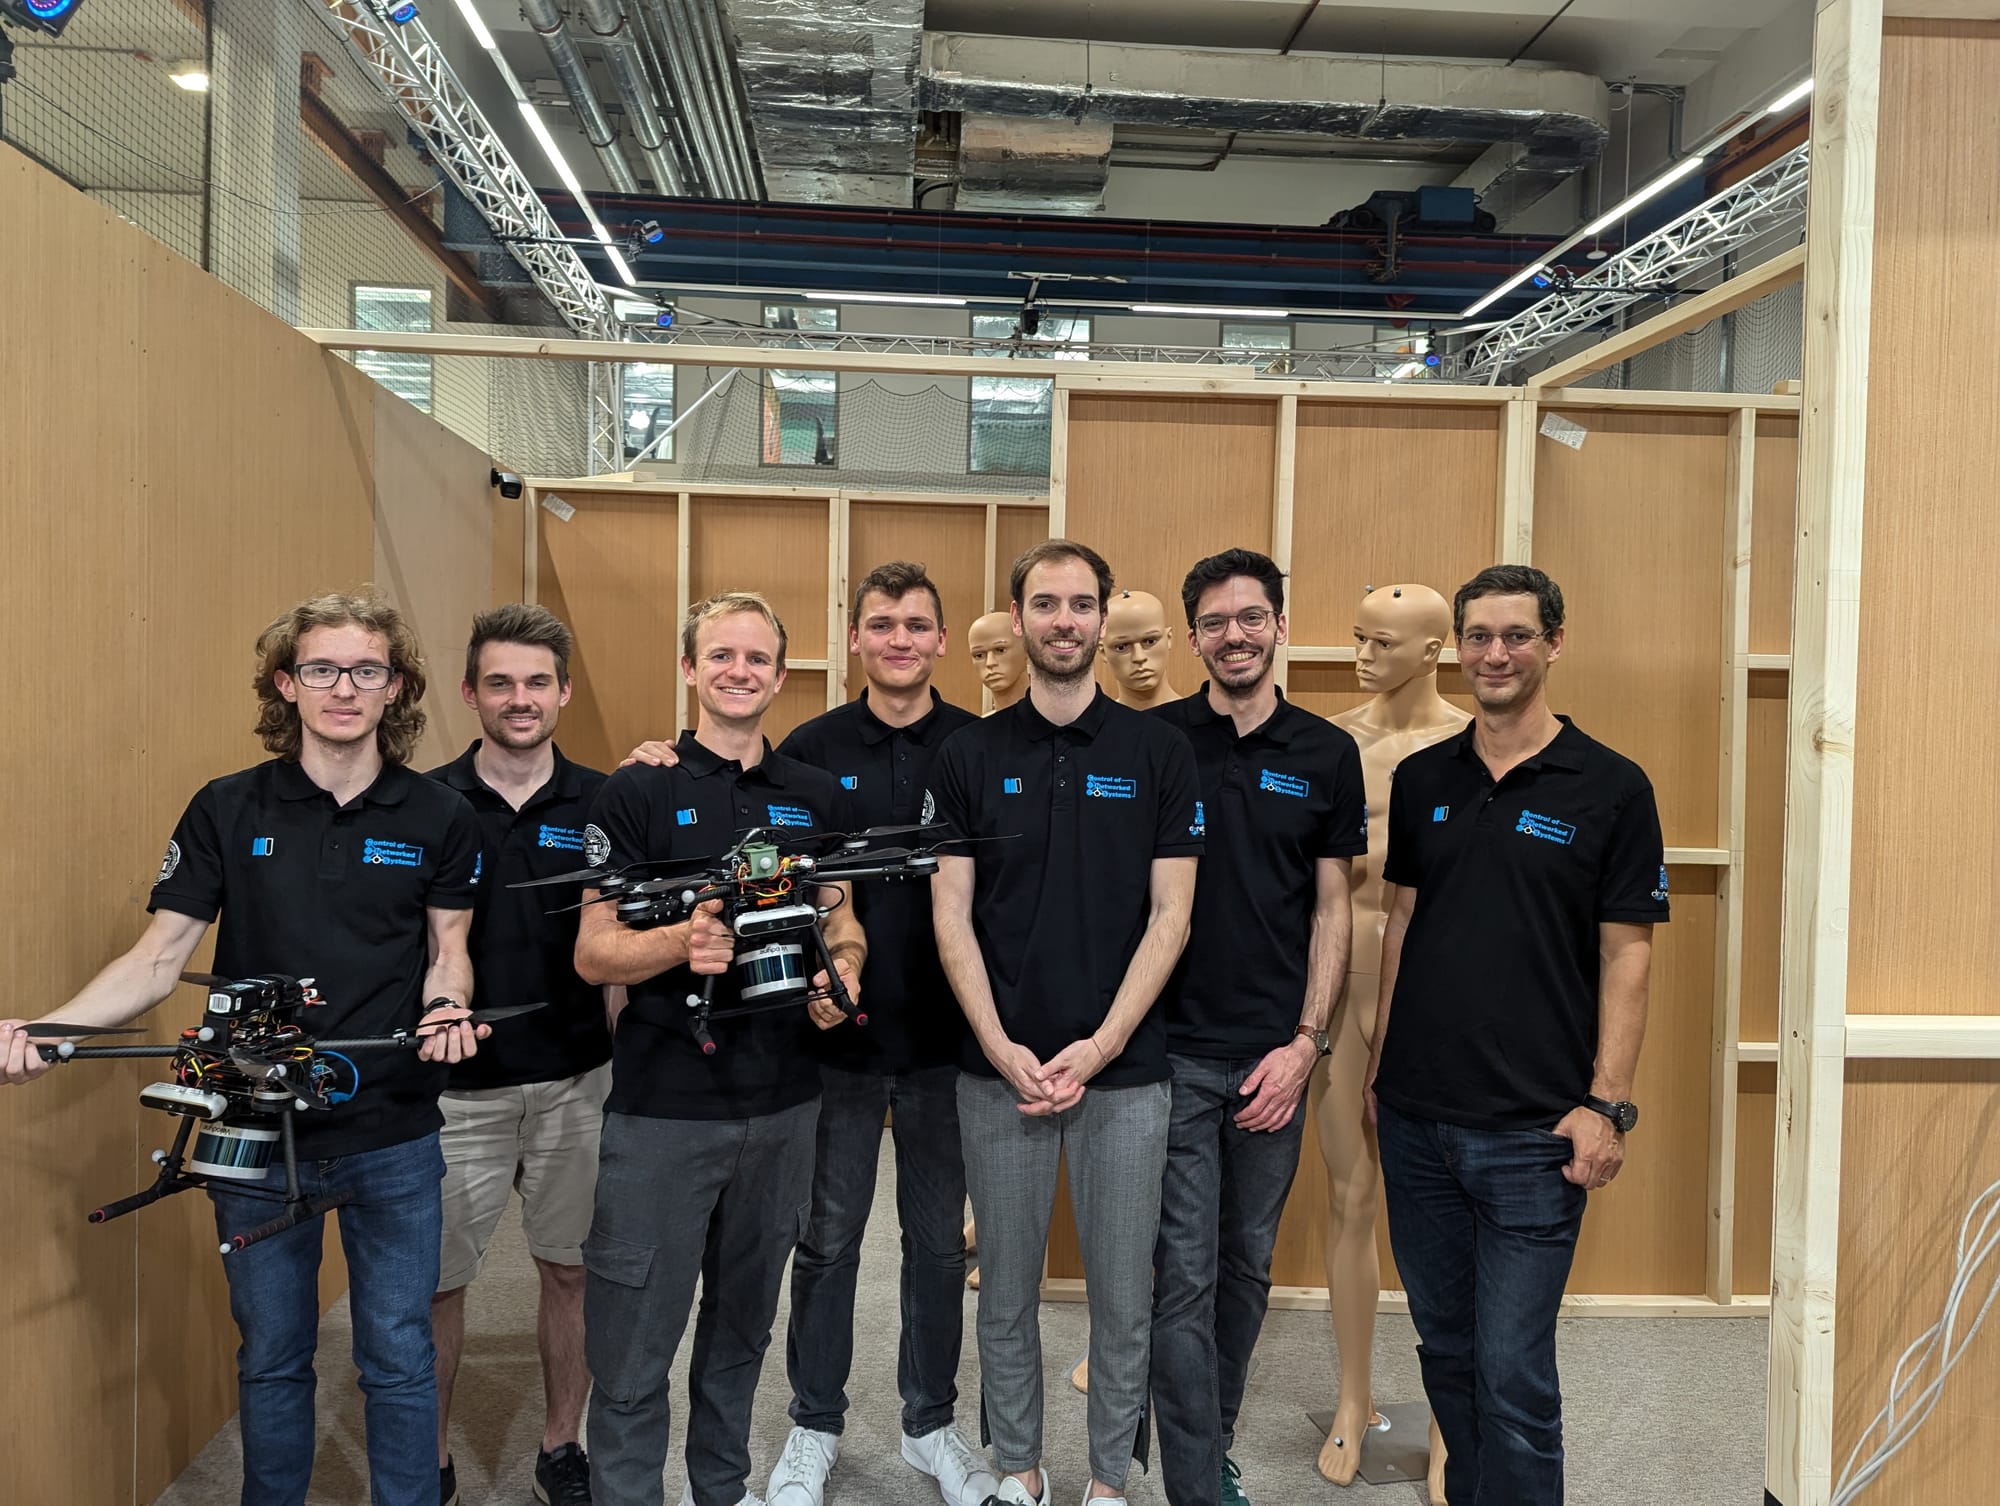
SAPIENCE - Sense & Avoid - a cooPeratIvE droNe CompEtition
Competition 1: Indoor Mapping and Object Detection Result: 2nd place (London, August 2024) Tasks: Mapping the Environment - Construct a map using two drones, navigating various hazards.Object Detection - Detect and note positions of objects like hazardous containers and injured mannequins.Aid Delivery - Deliver aid packages to mannequins at specific locations.Team Klagenfurt: Gilbert TannerLuca Di PiernoGeorg SteinthalerTim SchumannBen WesseJonas SpielerSupervisor: Prof. Stephan WeissThe competition occurred on 29th-30th August 2024 in London and Team Klagenfurt was able to solve all three tasks as specified above. To navigate the indoor environment we made use of ICP odometry based on RTABMAP fusing PointCloud data from the 3d lidar and depth camera. The environment was explored using 3d frontier exploration. ...