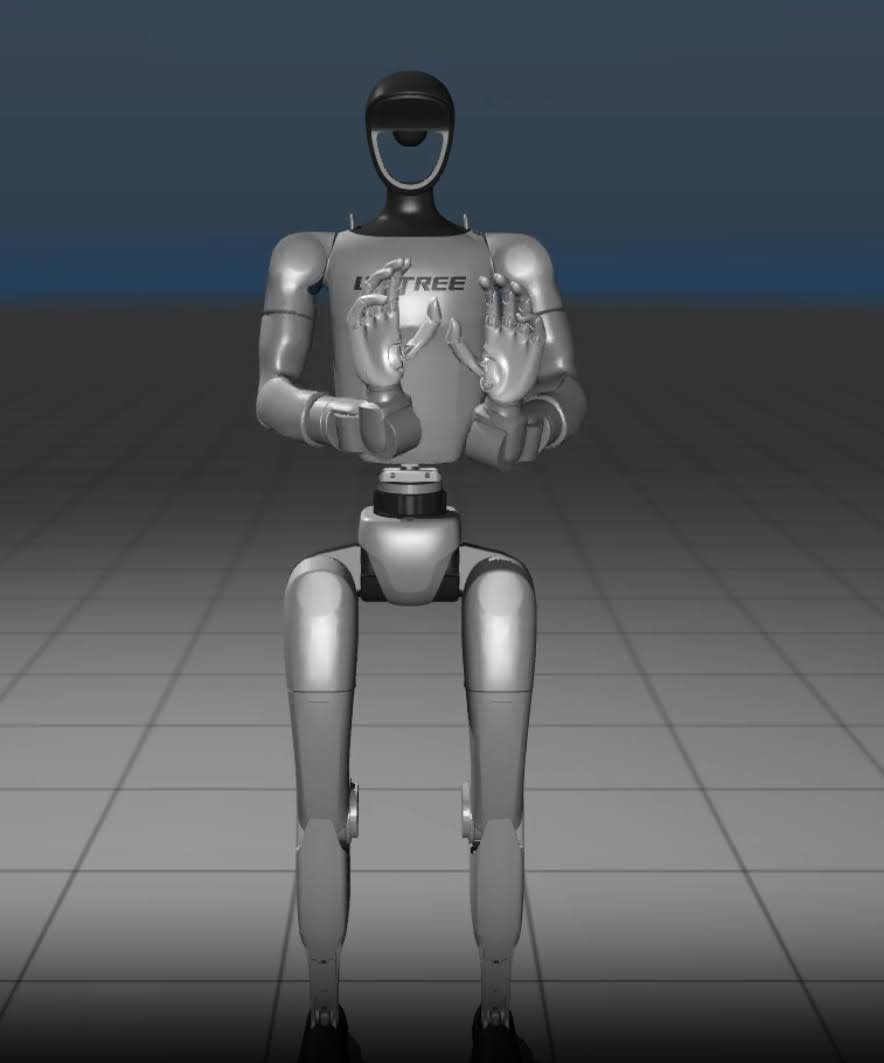
Sign Language Interpreter
This is my semester project for my Robotics, Systems and Control Master's at ETH Zurich, carried out from February to August 2026. The goal is to build a system that converts spoken language into continuous sign language motions for a humanoid robot. Sign language interpretation is essential for accessibility but the availability of professional interpreters is limited. A robotic interpreter could offer a scalable alternative by translating speech into sign language in real time. ...