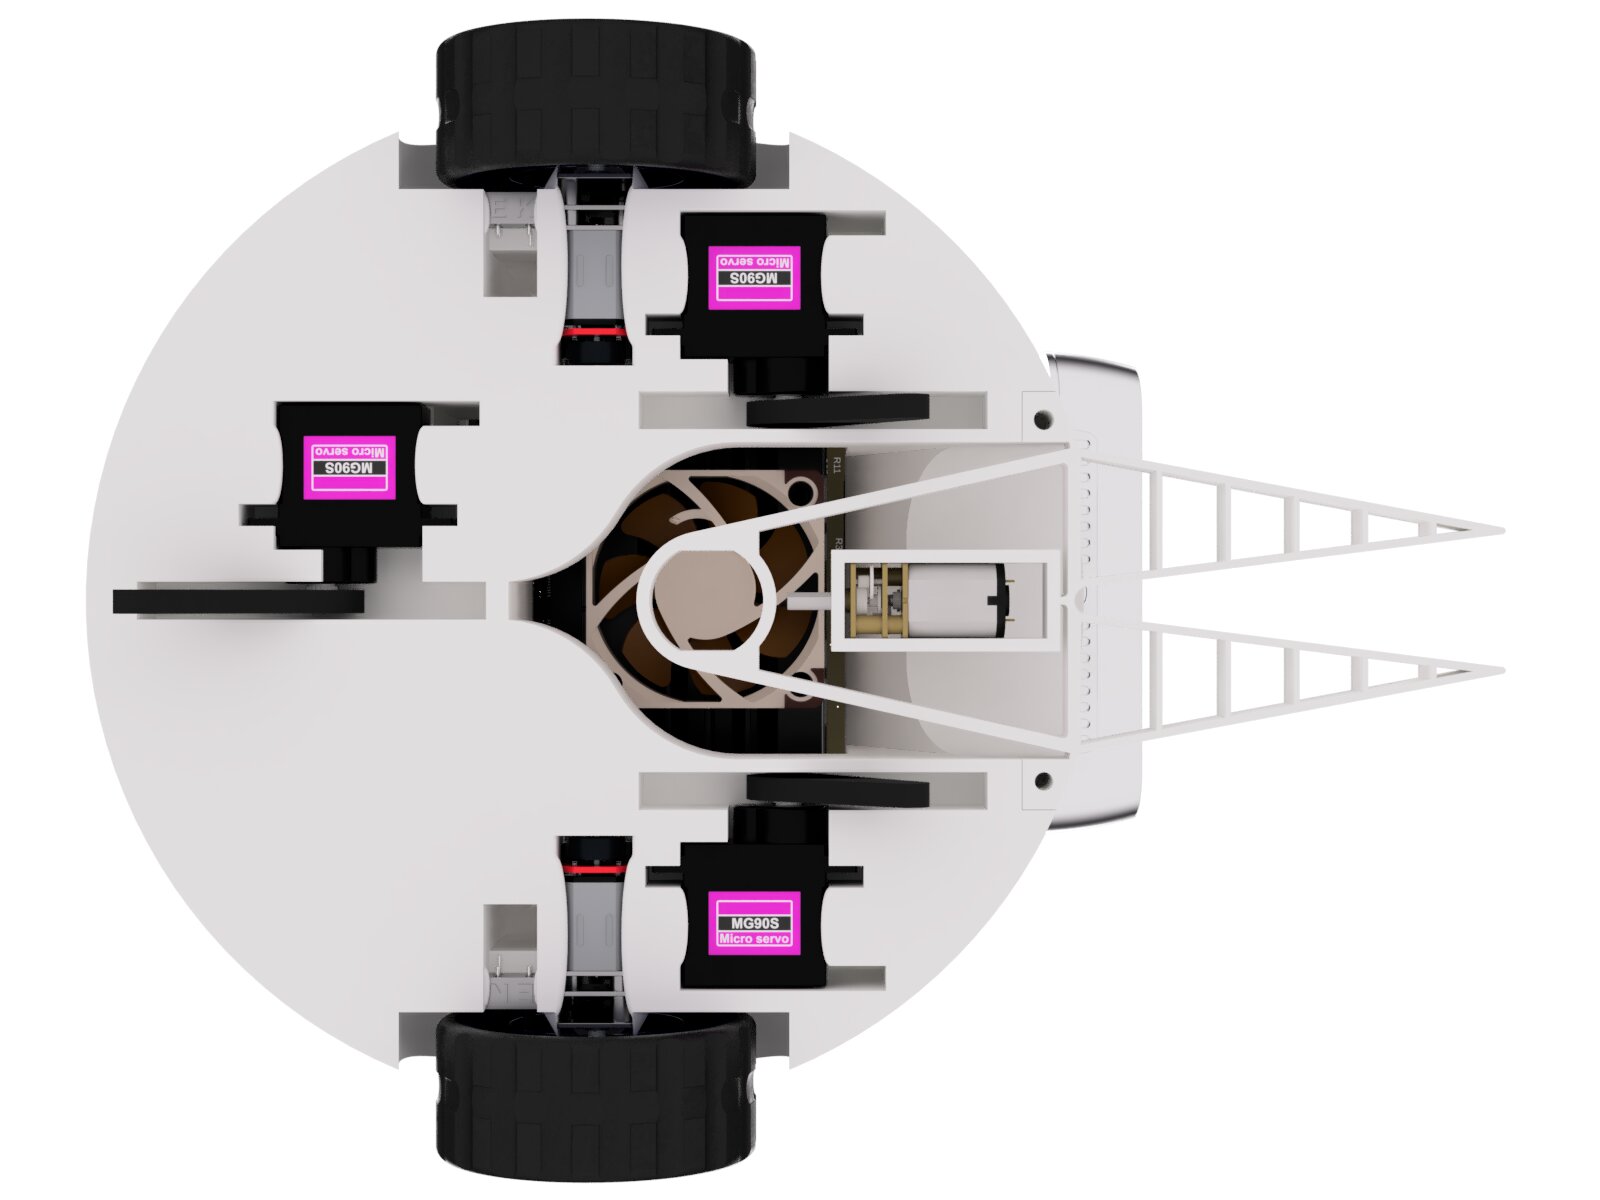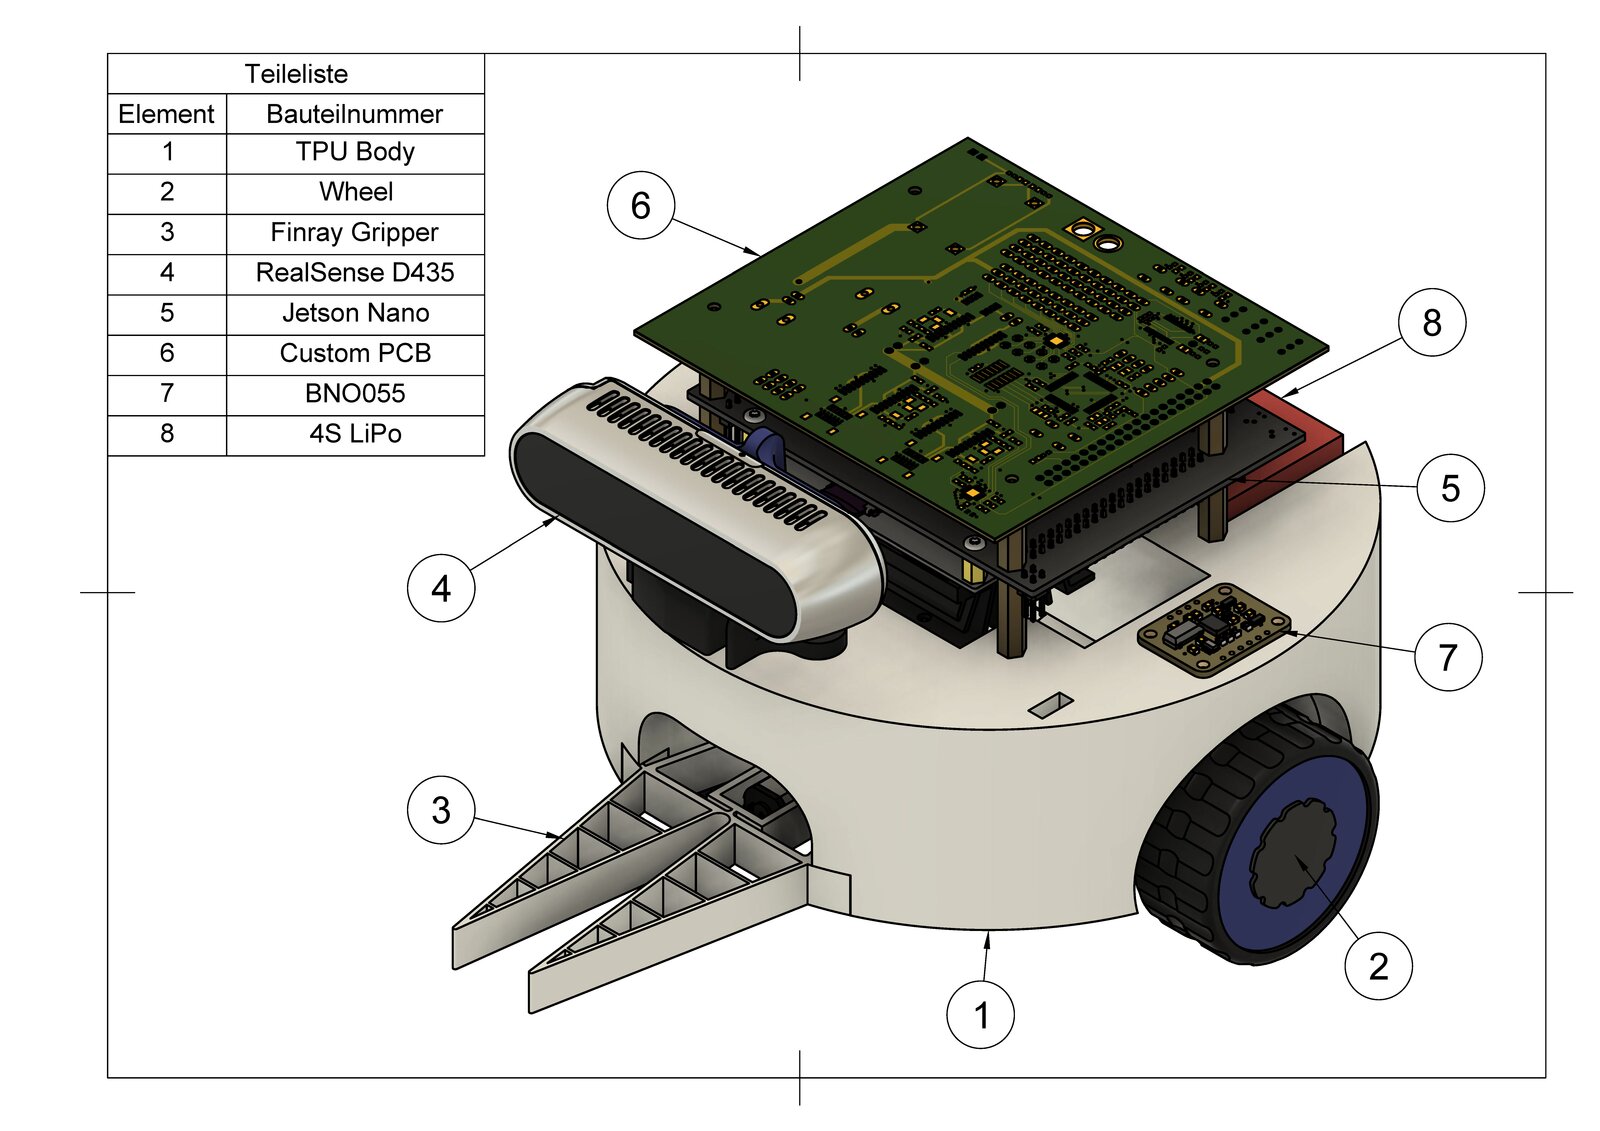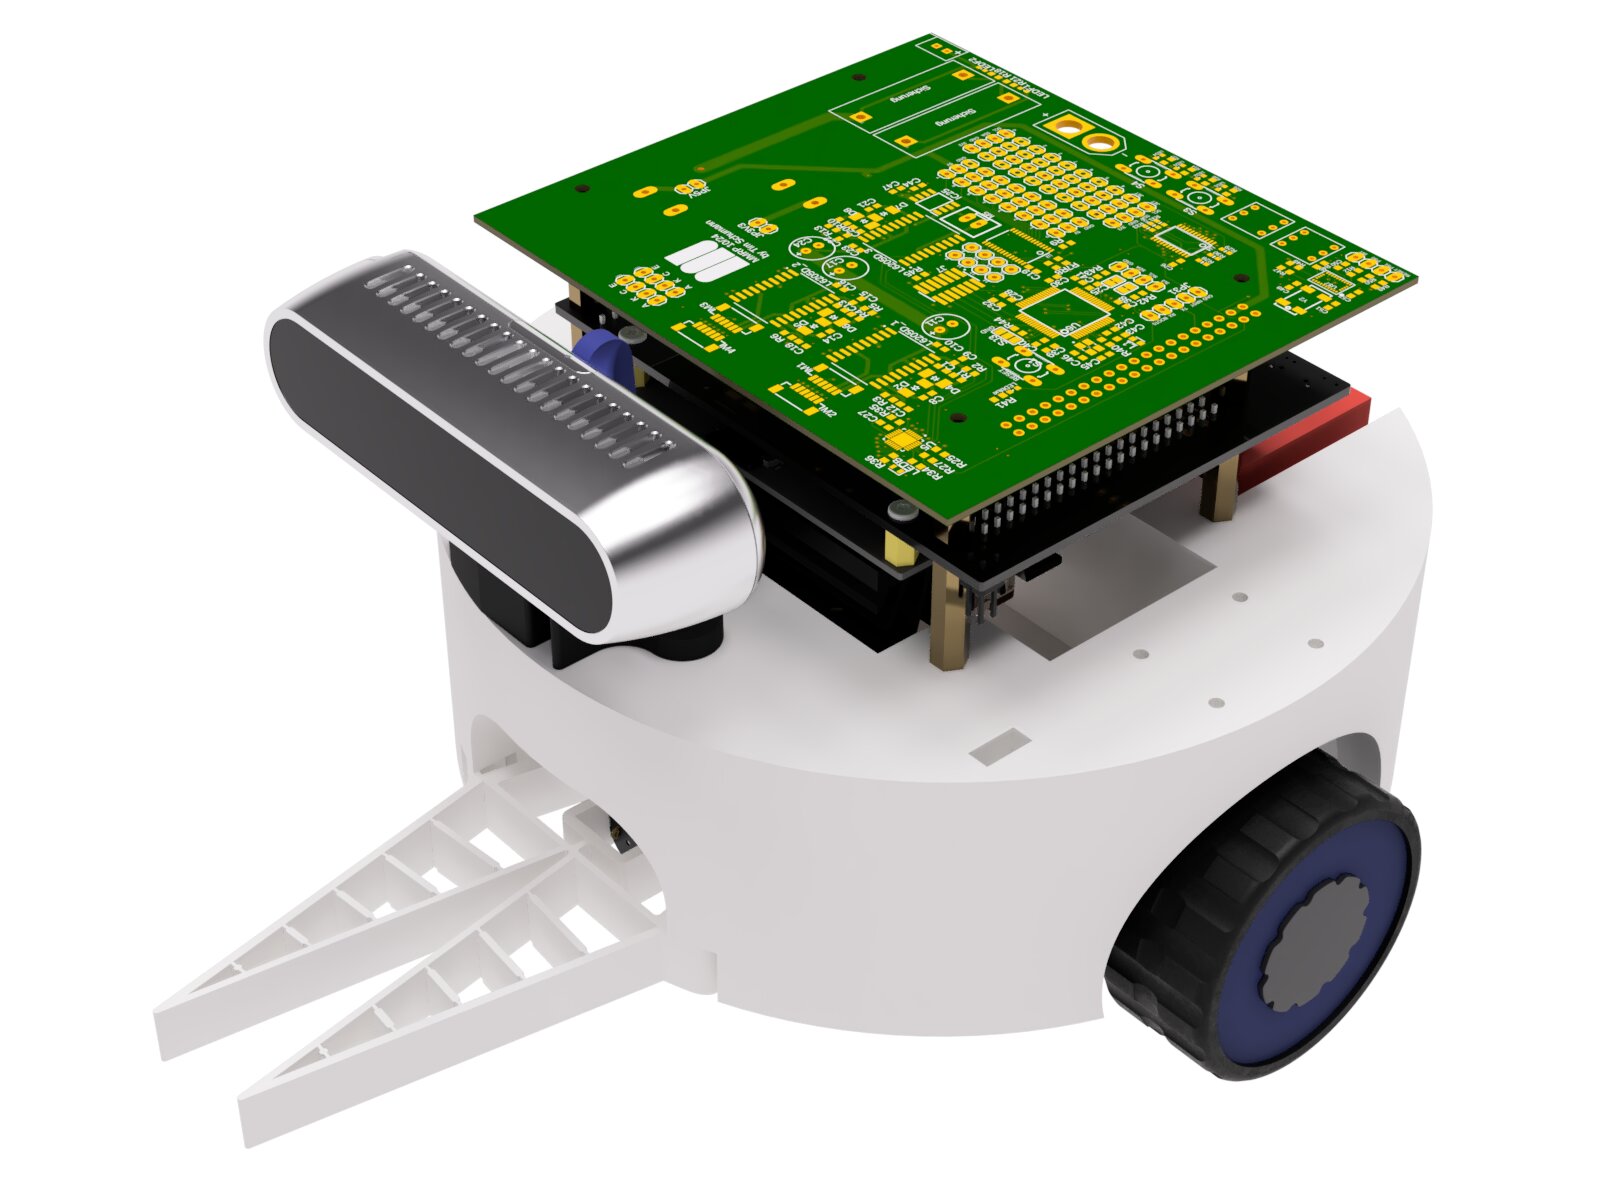
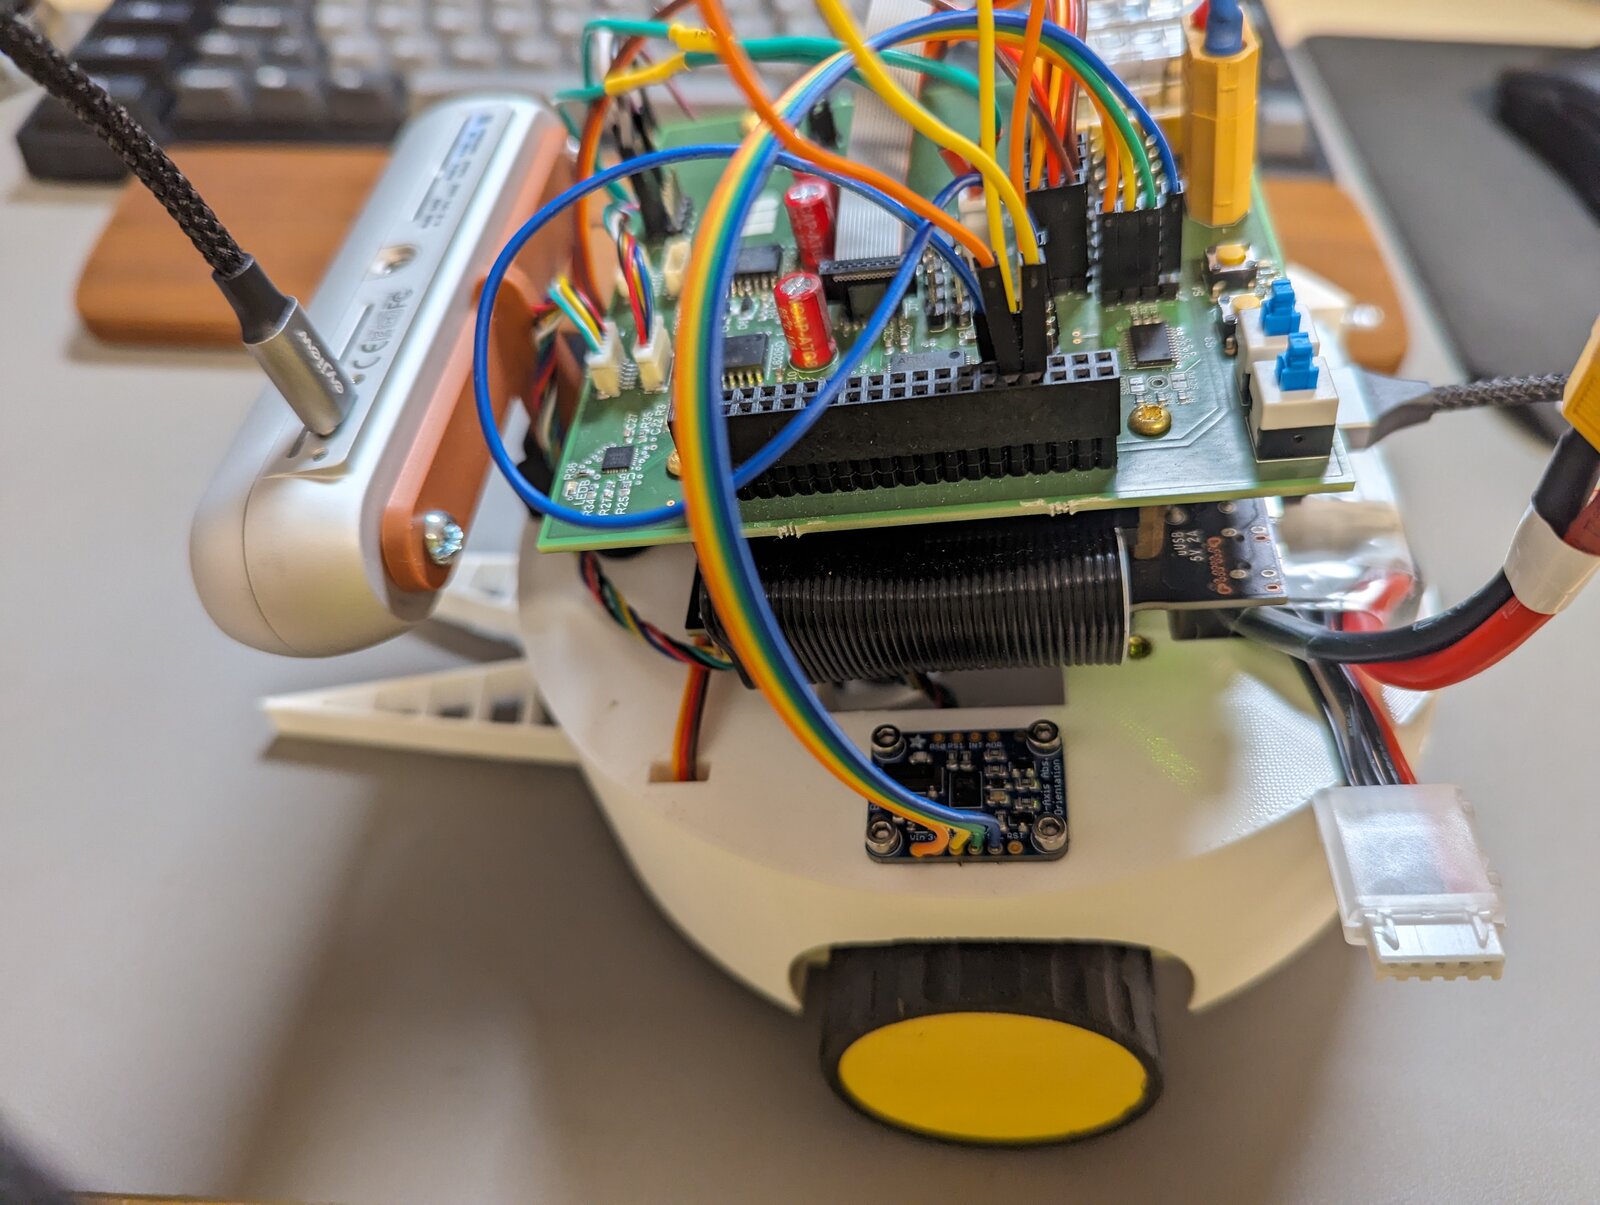
The Modular Mobile Robot Platform (MMRP) is a table-sized mobile robot platform that can be adapted and extended for different tasks. It is designed as a base for both research and education and combines an NVIDIA Jetson Nano for high-level computing with an STM32L476 microcontroller for low-level sensor and motor interfacing, connected through a custom PCB.
The circular robot drives on two wheels and is stabilized by three servos. It has a fin-ray gripper at the front. An Intel RealSense D435 depth camera sits on a servo on top of the robot and can tilt up and down by up to 110 degrees.
Hardware highlights:
- Jetson Nano and STM32L476RCT6 on a custom carrier PCB
- Intel RealSense D435 depth camera, BNO055 9-DOF IMU, optical and Hall encoders
- Four N20 gear motors with magnetic encoders, current sensing on one motor
- PCA9685 16-channel PWM driver for 8 servo and 8 PWM outputs
- 8 additional I²C channels via a TCA9548A multiplexer and the full 40-pin GPIO header
The software includes code samples for motor and servo control, reading the IMU and the STM32, using the RealSense camera, a simple web-based control interface, and a person-following demo.
- Team: Tim Schumann, Gilbert Tanner
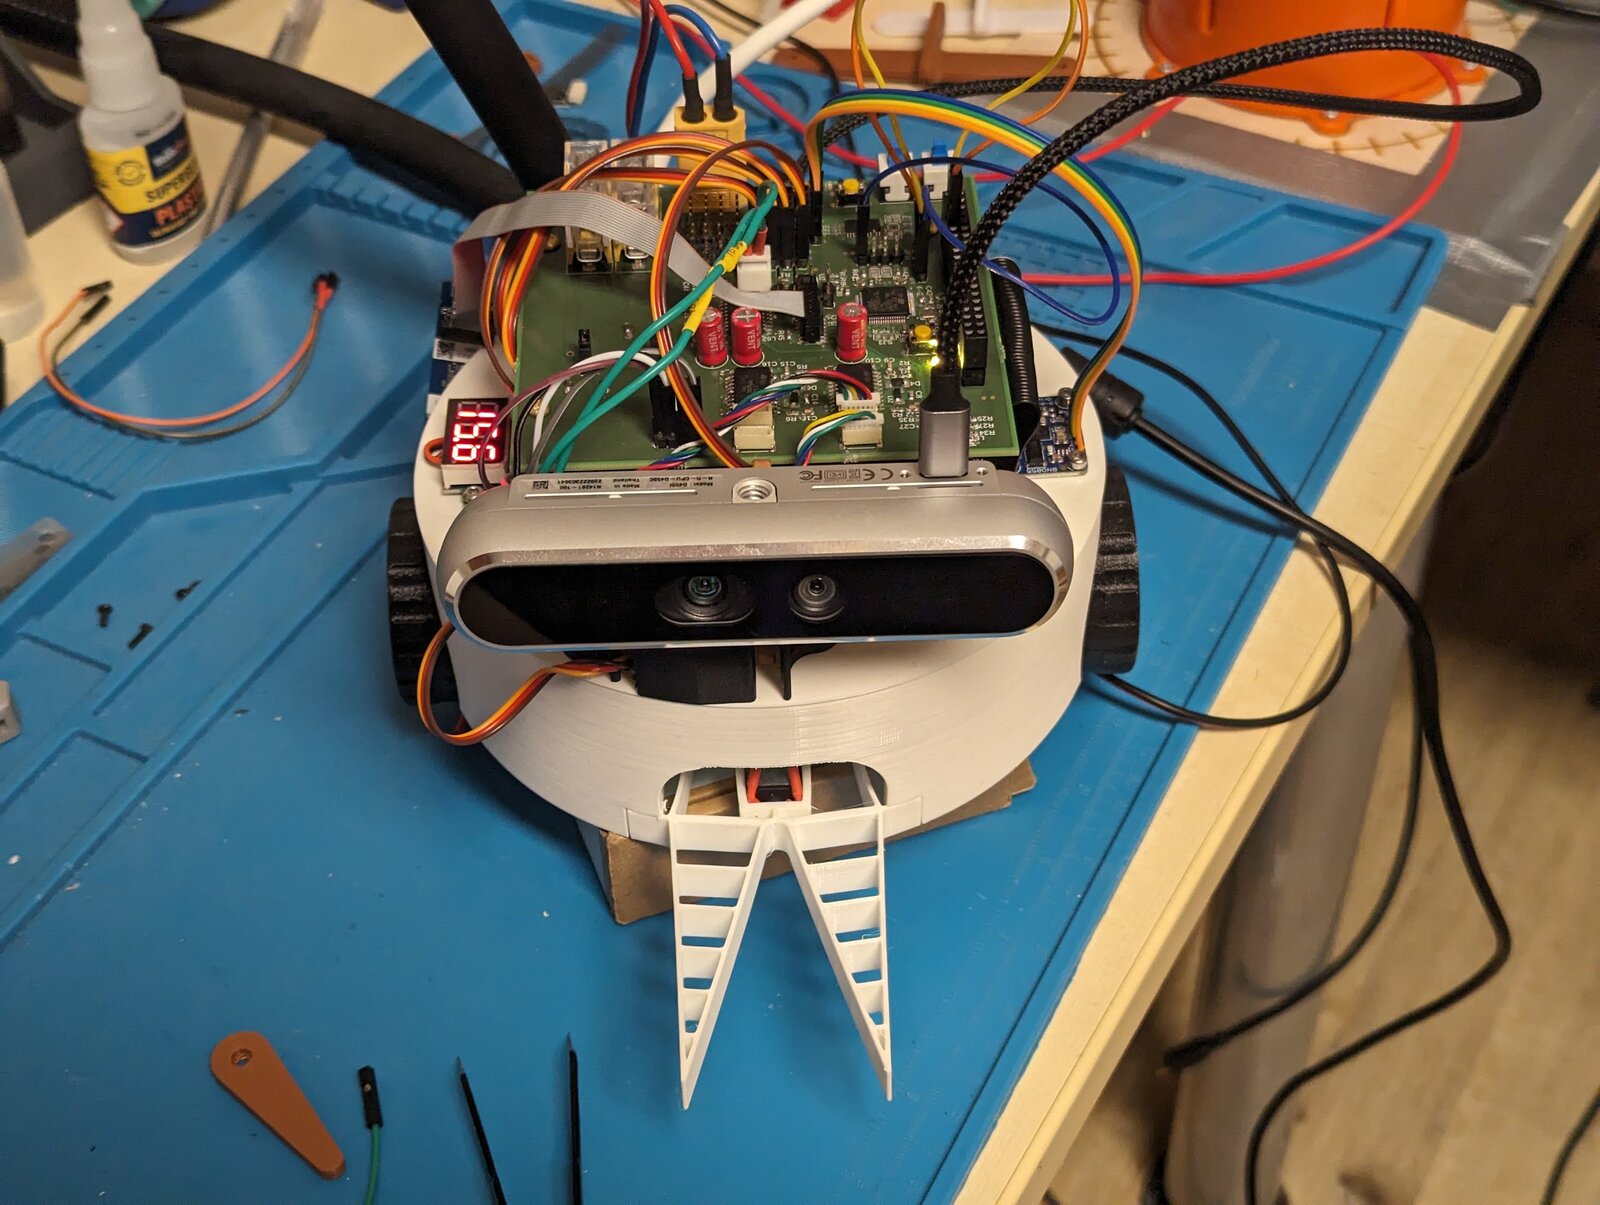
Person Following
Using the RealSense D435, the robot detects a person and follows them.
Design